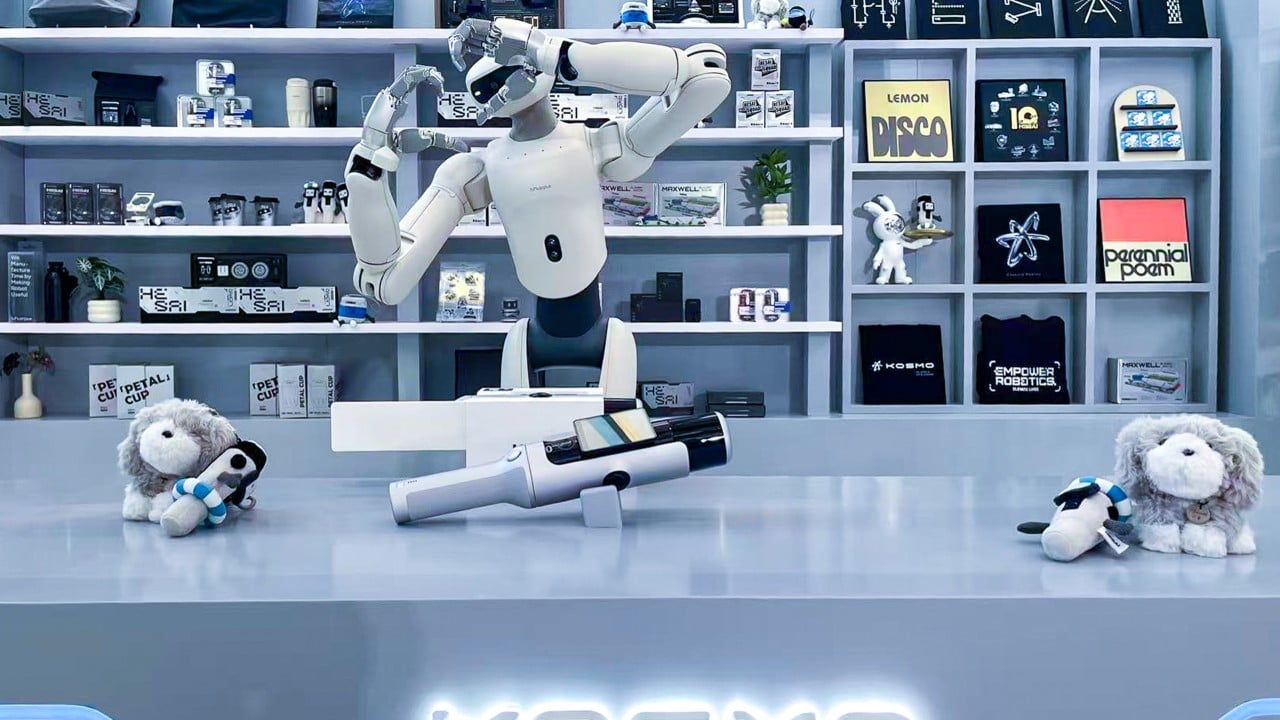
Hesai Group launched the Kosmo One 3D spatial camera alongside its Kosmo World platform in Shanghai on October 14, 2026, marking a calculated pivot from pure automotive lidar into physical AI training infrastructure and robotic hardware. By pairing high-resolution laser scanning, imaging, and inertial sensors with cloud reconstruction tools, the company aims to compress hours of manual 3D environment modeling into minutes of real-world capture for robotics developers.
For more than a decade, engineers who built autonomous vehicles and factory automation watched lidar companies fight a brutal war of attrition. Unit prices dropped from tens of thousands of dollars to a few hundred. Margins got squeezed by price wars in China's electric vehicle market. Regulatory scrutiny in Western capitals complicated cross-border supply chains. Anyone who spent time around automotive tier-one suppliers knew this day was coming. Lidar alone was becoming a commodity race, and commodity races reward scale and ruthless cost discipline over software stickiness. For another view, check out: this related article.
Hesai's move into spatial capture and embodied AI looks like a classic escape hatch from hardware commoditization. Yet calling it a simple product launch misses the deeper strategic bet. Hesai is trying to position itself upstream of the bottleneck slowing down physical AI: the shortage of accurate, affordable, real-world spatial data that teaches machines how physical rooms, shelves, and obstacles behave before a robot ever steps onto a live floor.
Why Lidar Alone Wasn't Enough for Hesai
Lidar has always been brilliant at measuring distance with laser pulses and terrible at telling you what a coffee mug is made of or why a wet floor reflects light differently than dry tile. In automotive driving, decades of road miles and specialized perception stacks helped bridge that gap. In indoor robotics, retail aisles, and warehouse bays, the environment changes constantly, objects get occluded, and hand-built 3D simulation scenes take far too long to create. Related reporting on the subject has been shared by The Verge.
Hesai built its reputation scaling lidar deliveries across autonomous driving and robotics. Management has openly framed the shift around moving from helping machines see the world to helping them understand and alter it, pairing spatial data tools with robotic actuation modules such as dexterous hands and body joints.
Moving from selling distance sensors to supplying reconstructed spaces and motion hardware changes where Hesai sits in the value chain—closer to robot training workflows and further from pure sensor price wars.
There is a hard business logic behind that expansion. Sensors are often spec'd in by procurement teams hunting for the lowest per-unit quote. Training environments and motion components become woven into a robotics developer's daily engineering loop. Once a team builds its simulation pipeline around a specific reconstruction format and sensor rig, switching costs rise sharply.
How Kosmo Turns Physical Rooms Into Training Data
At the core of the announcement is a two-part system. On the hardware side, Kosmo One combines lidar, a one-inch imaging sensor, and a high-precision inertial measurement unit (IMU) synchronized at the microsecond level to capture geometry, color, texture, and motion pose together. On the software side, Kosmo World—powered by Hesai's Kosmo Spatial Core—processes those captures using 3D Gaussian Splatting (3DGS), mesh generation, depth extraction, semantic segmentation, and generative gap-filling.
The workflow sounds deceptively straightforward. One operator walks through an indoor space, such as a 100-square-meter room, scanning geometry and visual appearance in roughly 15 minutes rather than paying a 3D modeling crew hundreds of hours to build a virtual twin by hand. From there, the reconstructed environment can feed simulation stacks like NVIDIA Isaac Sim and Isaac Lab or visual pipelines such as Unreal Engine, RenderMan, and Houdini.
Hesai has pointed to early demonstrations to argue the workflow works outside a lab. In a retail-style deployment involving a Sharpa robot at a Dairy Queen store, Hesai reported that scanning and reconstruction took about 15 minutes instead of roughly 300 hours of manual modeling, with task success reaching 99% and failure rates dropping to one-tenth of prior levels. Hesai also claims the platform can generate more than 10,000 training trajectories from a single scanned space.
Those numbers are eye-catching. They also deserve a hard, skeptical look.
The Gaps Between Demo Claims and Factory Reality
Every robotics engineer who has lived through a pilot-to-production transition knows the difference between a curated store walkthrough and a messy, unpredictable operation. A clean scan of a 100-square-meter space captures how the room looked at one moment in time. Real workplaces do not stay still. Pallets get stacked crookedly. Lighting shifts as doors open or overhead fixtures age. People walk past blind corners.
Even more importantly, 3D Gaussian Splatting and generative completion have real trade-offs. Splatting excels at photorealistic rendering and rapid visual reconstruction, yet visual realism is not the same thing as physical accuracy or collision fidelity. When generative models fill in unscanned corners or infer hidden surfaces, they make educated guesses. A robot grasping a fragile object or navigating tight clearances cannot afford a plausible-looking hallucination where a solid shelf or cable actually sits.
Consider a hypothetical example to see where friction can appear. Suppose a warehouse team scans a packing station in 15 minutes and generates thousands of simulated trajectories overnight. If the synthetic variations over-rely on visually smooth reconstructions rather than true contact physics, deformable packaging, and sensor noise, a policy trained in simulation can still stumble the first time a box is slightly crushed or glossy shrink-wrap glares under warehouse LEDs.
There are commercial questions left unanswered at launch as well. Hesai did not immediately publish pricing, general availability dates, or regional rollout details for Kosmo. Nor have those 99% task success figures or trajectory multiplication claims been independently verified across third-party benchmarks.
Data Governance, Privacy, and Ecosystem Friction
Scanning physical spaces at scale introduces headaches that have nothing to do with laser wavelengths or frame rates. A handheld or robot-mounted spatial camera walking through an office, retail store, clinic, or factory floor does not just record walls and shelves. It captures employees' faces, computer screens, whiteboards, proprietary layouts, and sensitive documents.
Any enterprise considering spatial scanning has to answer basic governance questions before turning a camera on:
- Access and retention: Who is authorized to capture scans, where are raw point clouds and 3D assets stored, and how long do they remain in cloud queues?
- Masking and consent: How are bystanders, workers, and confidential screens redacted or excluded so training datasets do not become privacy liabilities?
- Lock-in and exportability: Can teams move meshes, depth maps, and trajectories cleanly into their own internal simulation tools if their stack evolves?
Hesai is also stepping into an ecosystem where robotics teams already have strong opinions about their toolchains. Many labs rely on custom teleoperation datasets, multi-camera rigs, or proprietary physics simulators tuned specifically to their actuators. Selling a spatial camera and world engine means convincing engineers that fast 3D environment capture solves a bigger bottleneck than collecting more human demonstration episodes.
What Hesai's Bet Signals for Robotics Buyers
Look beyond the marketing around physical AI and you see a practical truth about industrial automation. Hardware breakthroughs rarely fail in isolation; they stall because feeding data into the pipeline is slow, expensive, and brittle. If Kosmo genuinely cuts environment-creation time from weeks of manual 3D modeling to a single afternoon scan, robotics teams can test layouts and edge cases far faster than before.
At the same time, buyers should treat rapid 3D reconstruction as an accelerator for iteration, not a magic guarantee of reliability. Demand proof on your own messy floor conditions, lock down data governance rules before scanning live operations, and pair any simulated training with strict real-world validation before letting autonomous machines work unsupervised around people and expensive equipment.